Research Interests
研究分野
- ロボットマニピュレーション
- バイラテラル制御
- 力制御
- 模倣学習
- VLA (Vision-Language-Action)
- マルチモーダル融合
- Robot Manipulation
- Bilateral Control
- Force Control
- Imitation Learning
- VLA (Vision-Language-Action)
- Multimodal Fusion
Research Projects
研究プロジェクト
Explicit Learning and Control of Robot Motion Characteristics through Imitation Learning
模倣学習によるロボット動作特性の明示的学習と制御
2025.04 - Present 2025.04 - 現在Research Challenge
研究課題
When grasping objects, humans can consider the properties of objects and the state of the environment to perform appropriate actions. However, current robots that simply imitate human motion cannot consider the nature of the motion itself, and lack the ability to adaptively control speed and force according to the situation.
人間は物を掴む際に物体の特性や環境の状態を考慮して動作を行うことができます. しかし, 現在のロボットはただ人間の動作を模倣するだけでは, 動作の性質まで考慮することができず, 速度や力加減を状況に応じて適応的に制御する能力が不足しています.
Research Approach
研究アプローチ
Collecting high-quality data of human motion including force and speed through bilateral control. Building an imitation learning framework that explicitly learns behavioral characteristics and enables intentional control by humans and VLM.
バイラテラル制御を活用することで, 人間が行う動作の力加減や速度の高品質なデータを収集. 行動特性を明示的に学習し, 人間やVLMが意図的に制御できる模倣学習フレームワークを構築.
Research Goal
研究目標
Realizing robots that explicitly learn the nature of motion and can adaptively control speed and force according to the properties of objects and the state of the environment.
動作の性質を明示的に学習し, 物体の特性や環境の状態に応じて速度や力加減を適応的に制御できるロボットの実現.
Imitation Learning Based on Bilateral Control Utilizing Visual and Natural Language Information
視覚・自然言語情報を活用したバイラテラル制御に基づく模倣学習
2024.04 - 2025.03Research Challenge
研究課題
Traditional robot imitation learning focuses primarily on position and trajectory reproduction, making it unsuitable for delicate operations requiring force control, such as handling soft objects and controlling grasping force.
従来のロボット模倣学習は位置や軌道の再現に偏っており, 柔らかい物体の取り扱いや物体を把持する力など力制御が必要な繊細な操作には不向きである.
Research Approach
研究アプローチ
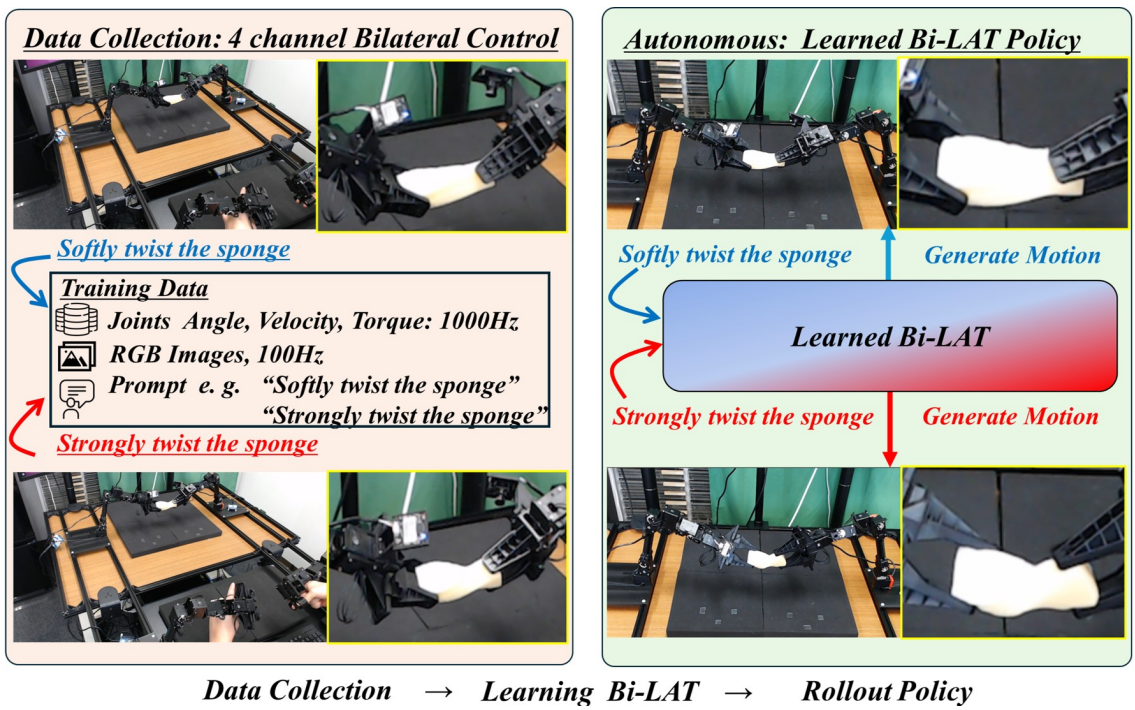
Integrated visual, force, and natural language information using a Transformer model. Leveraging position, velocity, and torque data from bilateral control, built an imitation learning framework that can directly translate everyday language instructions like "softly grasp" and "twist strongly" into force control.
視覚・力覚・自然言語情報をTransformerモデルで統合. バイラテラル制御から得られる位置・速度・トルク情報を活用し, 「優しく掴んで」「強くひねって」といった日常的な言語指示を直接力制御に変換できる模倣学習フレームワークを構築.
Results
結果
Achieved higher success rates than conventional methods on tasks such as "Cup Stack" and "Twist Sponge". Demonstrated that language instructions can be effectively converted to force control. This research served as the foundation for the current master's research on behavioral intelligence.
"Cup Stack"や"Twist Sponge"などのタスクで従来手法を上回る成功率を達成. 言語指示が力制御に有効に変換されることを実証しました. 本研究は現在の修士研究における行動知能研究の基盤となりました.
Conferences
学会発表
International Conferences
国際学会
RO-MAN 2025
IEEE International Conference on Robot and Human Interactive Communication
IEEE International Conference on Robot and Human Interactive Communication
Accepted
査読あり
Oral Presentation
口頭発表
Bi-LAT: Bilateral Control-Based Imitation Learning via Natural Language and Action Chunking with Transformers
Bi-LAT: Bilateral Control-Based Imitation Learning via Natural Language and Action Chunking with Transformers
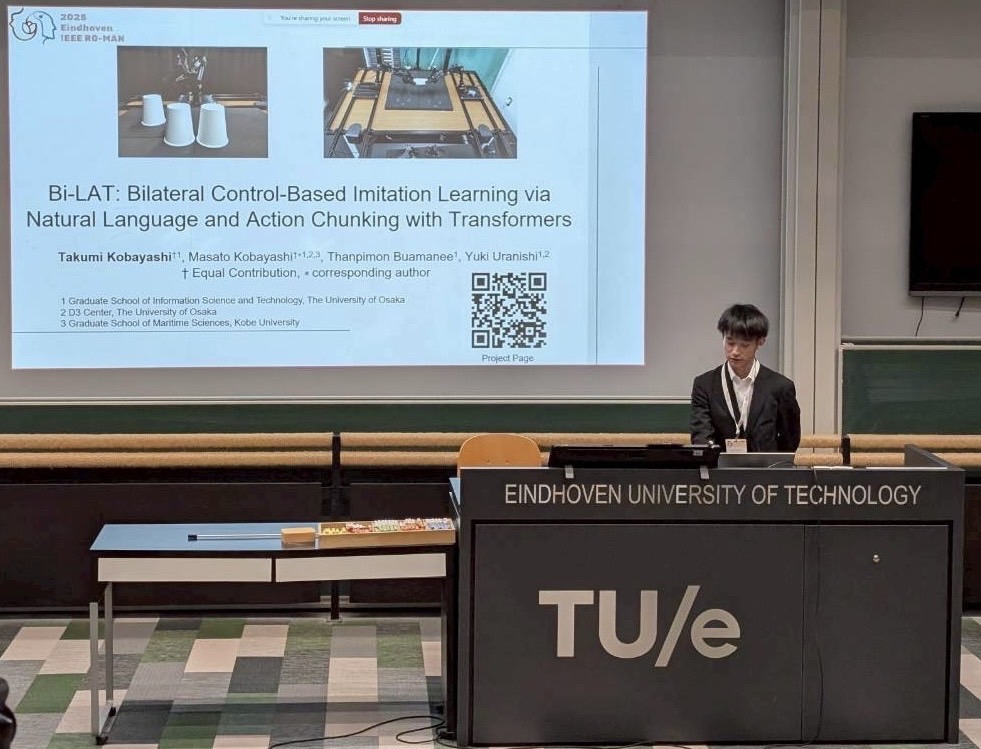
エイントホーフェン(オランダ)での発表の様子
Presentation at Eindhoven, Netherlands
Domestic Conferences
国内学会
ROBOMECH 2025
The 2025 JSME Conference on Robotics and Mechatronics
日本機械学会ロボティクス・メカトロニクス講演会2025
Poster Presentation
ポスター発表
言語情報を活用したバイラテラル制御に基づく模倣学習
Imitation Learning Based on Bilateral Control Utilizing Language Information
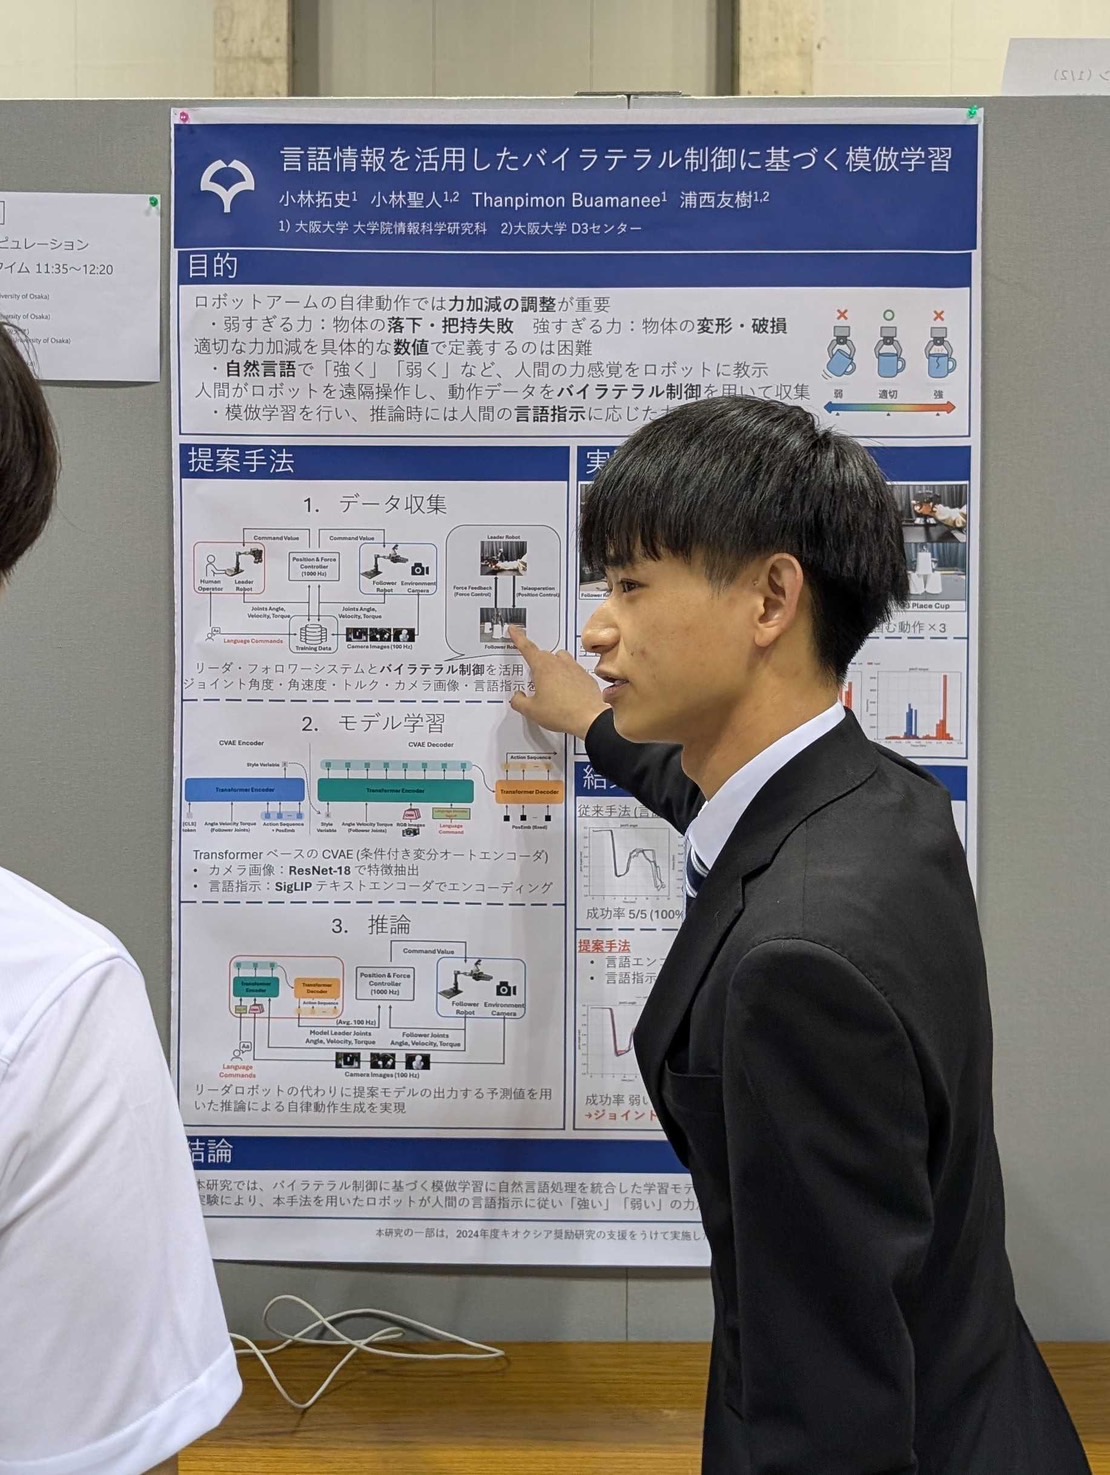
山形での発表の様子
Presentation at Yamagata
Conference Proceedings
国際会議論文
Bi-LAT: Bilateral Control-Based Imitation Learning via Natural Language and Action Chunking with Transformers
IEEE RO-MAN 2025 (International Conference on Robot and Human Interactive Communication)
Journal Publications
論文誌
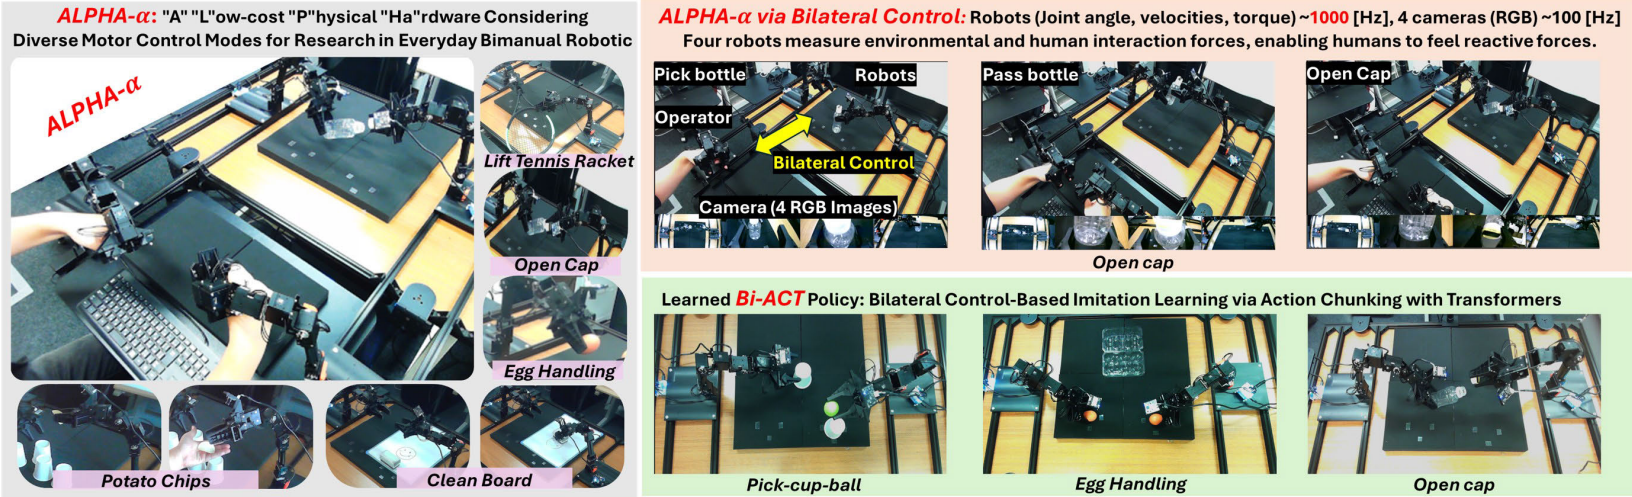
ALPHA- α and Bi-ACT Are All You Need: Importance of Position and Force Information/ Control for Imitation Learning of Unimanual and Bimanual Robotic Manipulation With Low-Cost System
IEEE Access, 2025
Theses
学位論文
卒業論文
Graduation Thesis
視覚・自然言語情報を活用したバイラテラル制御に基づく模倣学習
Imitation Learning Based on Bilateral Control Utilizing Visual and Natural Language Information
大阪大学 基礎工学部 情報科学科, 2025
School of Engineering Science, The University of Osaka, 2025
Internships
インターンシップ
株式会社Phoxter
Phoxter Corporation
R&D 長期インターンシップ
R&D long-term internship
物体認識・姿勢推定・行動検知などの画像認識モデルに関する研究開発および実装
R&D and implementation on image recognition machine leraning models including object recognition, pose estimation, and action detection
2025年11月~
Since November 2025
ソニーグループ株式会社
Sony Group Corporation
R&D 職場密着インターンシップ(4週間)
R&D internship (4 weeks)
シミュレータ上でVLMと触覚センサを活用したロボットマニピュレーターの動作計画・制御
Robot manipulator motion planning and control using VLM and tactile sensors on simulator
2025年9月
September 2025