小林 拓史
Takumi Kobayashi
Takumi Kobayashi
小林 拓史
Physical AIに向けた人間レベルの行動知能を持つ自律ロボットアームの研究
Research on autonomous robotic arms with human-level behavioral intelligence towards Physical AI
大阪大学大学院情報科学研究科の博士前期課程2年で, Physical AIに向けたロボット行動知能を専門に研究しています.
人間のような柔軟で適応的な動作をロボットが実現できる未来を目指し, ロボット制御, 模倣学習, マルチモーダルAIといった技術を組み合わせた研究に取り組んでいます.
私の研究の核心は, ロボットが「動作の性質」を理解し, 状況に応じて速度や力加減を自在に制御できる行動知能を獲得することです. 従来のロボットモデルでは正確な動作は可能である一方, 力加減や速度, 動作の滑らかさといった「動作の性質」において人間との差が依然として存在すると考えています. 研究を通して, ロボットが人間と同等の巧みさで多様なタスクをこなせる世界の実現を目指しています.
I am a second-year Master's course student at the Graduate School of Information Science and Technology, The University of Osaka, specializing in robotic behavioral intelligence towards Physical AI.
My research aims to enable robots to perform flexible and adaptive motions like humans, by combining technologies such as robot control, imitation learning, and multimodal AI.
The core of my research is to enable robots to understand "motion characteristics" and acquire behavioral intelligence that can freely control speed, force application, and motion smoothness according to the situation. While conventional robot models can achieve accurate movements, I believe there still exists a gap between humans and robots in "motion characteristics" such as force modulation, speed control, and motion smoothness. Through this research, I aim to realize a world where robots can perform diverse tasks with the same dexterity as humans.
Research Highlights
研究ハイライト
Robotics
ロボット工学
Bilateral control techniques for robot arm control systems
バイラテラル制御技術を用いたロボットアーム制御システムの研究
AI & Machine Learning
人工知能と機械学習
Building imitation learning frameworks that explicitly learn motion characteristics and enable control by humans and VLMs
ロボット動作性質を明示的に学習し,人間やVLMが制御可能な模倣学習フレームワークの構築
Multimodal Fusion
マルチモーダル融合
Robotic model that integrates visual, haptic, and linguistic information to realize context-aware motion decisions
視覚・触覚・言語情報を統合し状況に応じた動作決定を実現するロボットモデル
Research Robots
研究ロボット
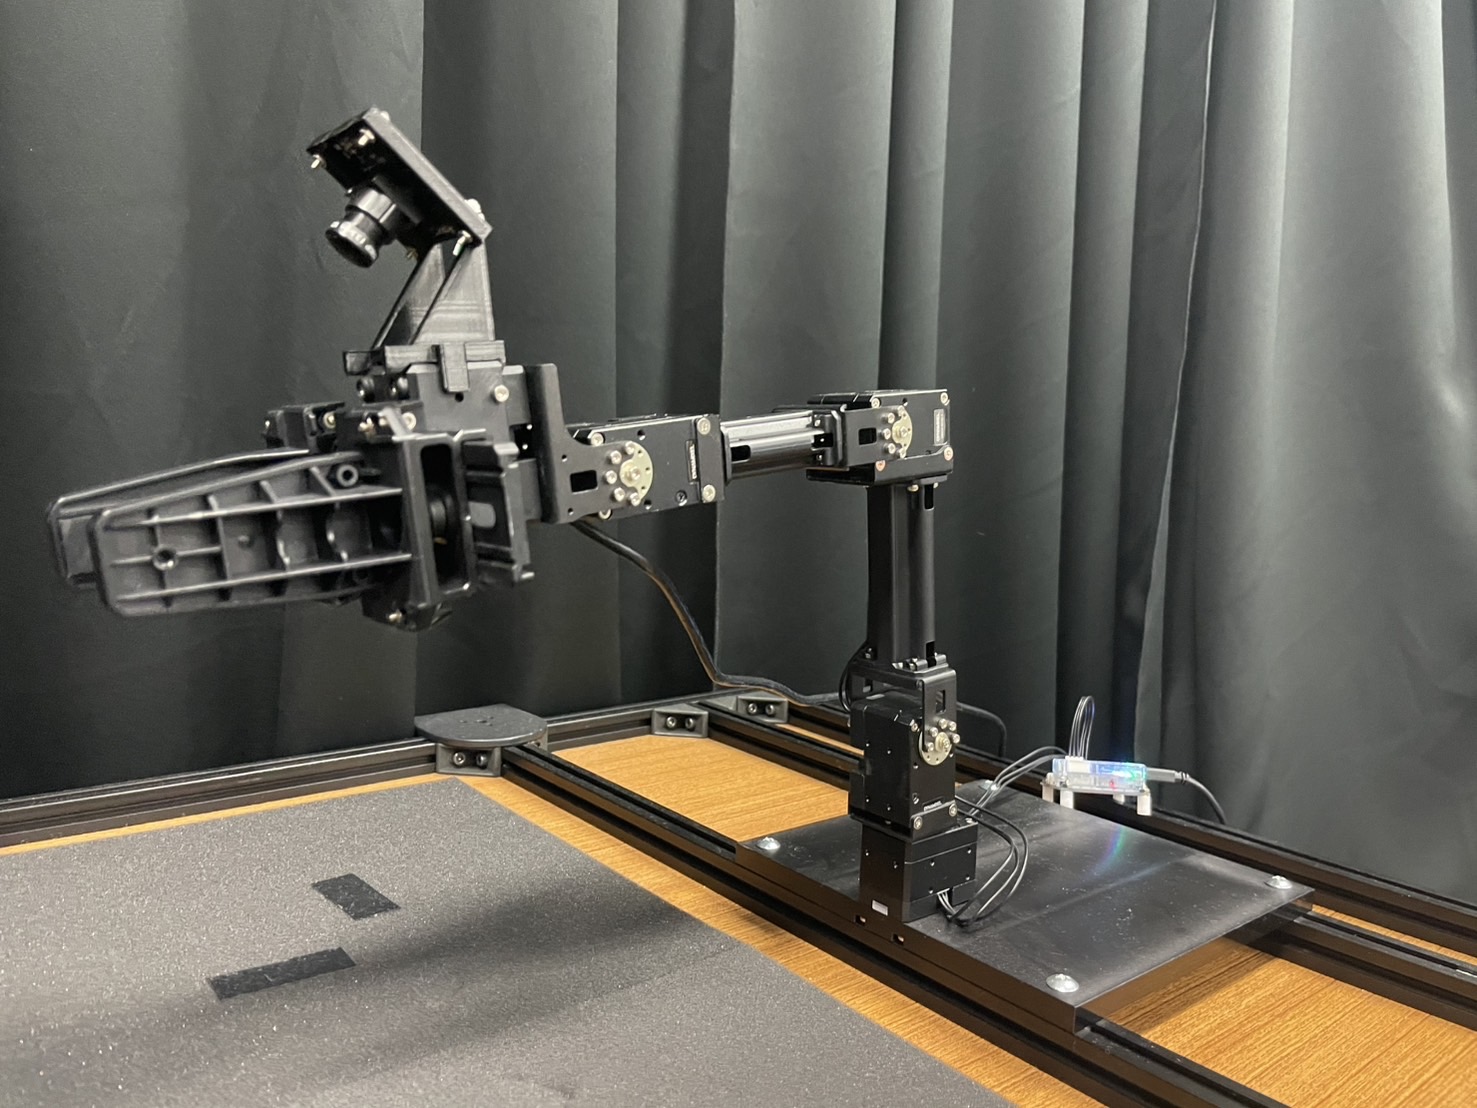
OpenMANIPULATOR-X
ROBOTISの4DOFロボットアーム
4-DOF robot arm by ROBOTIS
バイラテラル制御・模倣学習
Bilateral Control / Imitation Learning
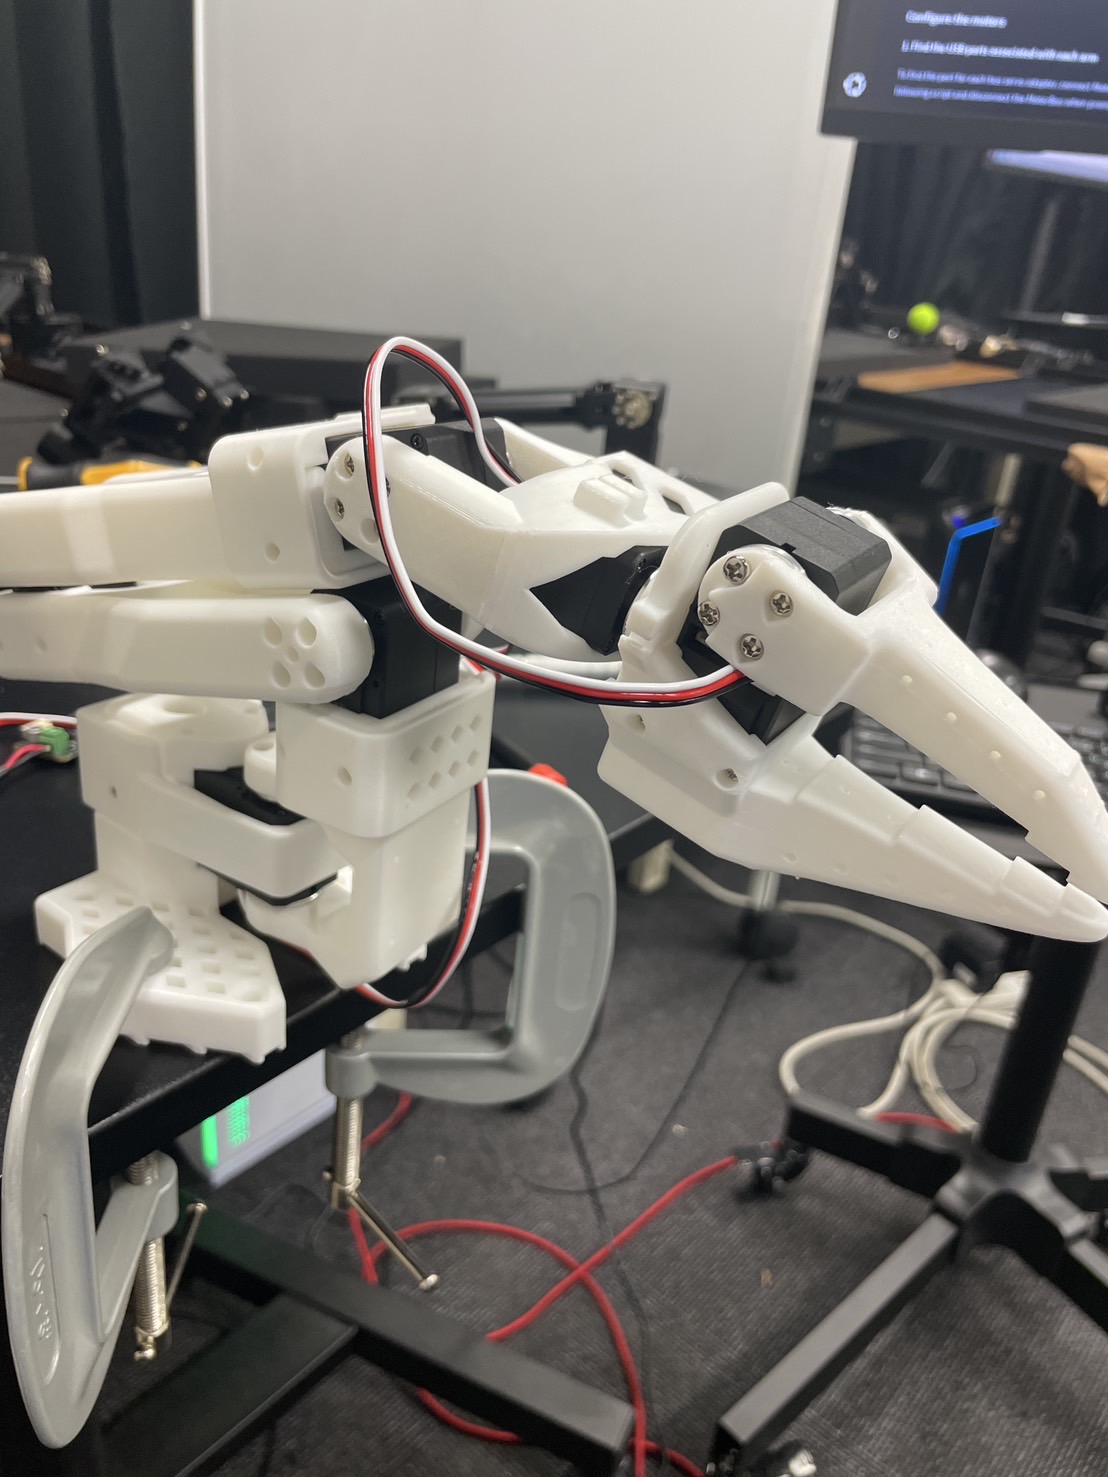
SO-101
オープンソースロボットアーム
Low-cost open-source robot arm
模倣学習・強化学習
Imitation Learning / Reinforcement Learning
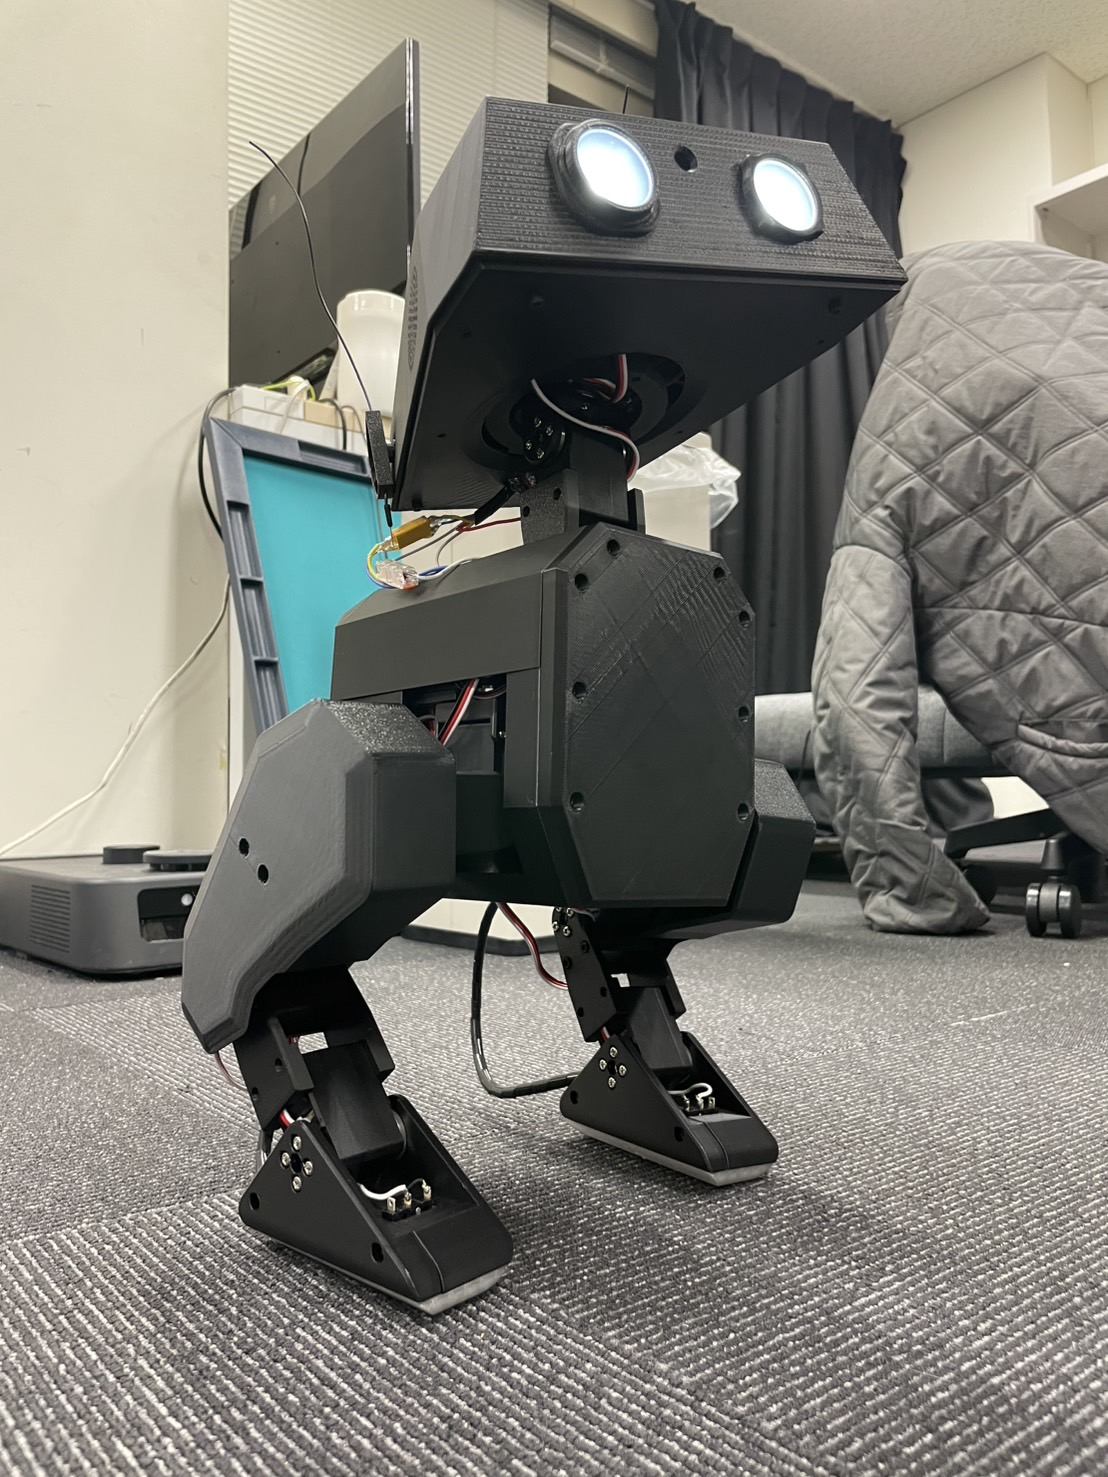
Open Duck Mini
オープンソース二足歩行ロボット
Open-source bipedal robot
シミュレータ・強化学習
Simulator / Reinforcement Learning
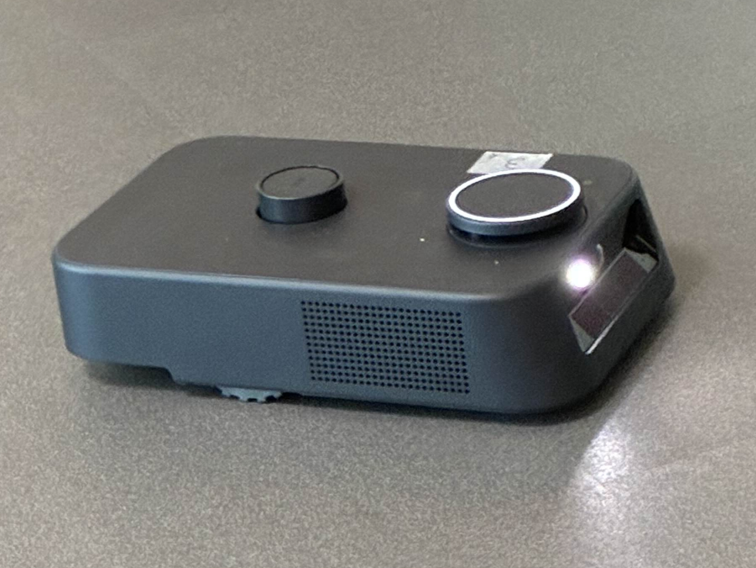
Kachaka
Preferred Roboticsの自律移動ロボット
Autonomous mobile robot by Preferred Robotics
ナビゲーション・経路計画
Navigation / Path Planning